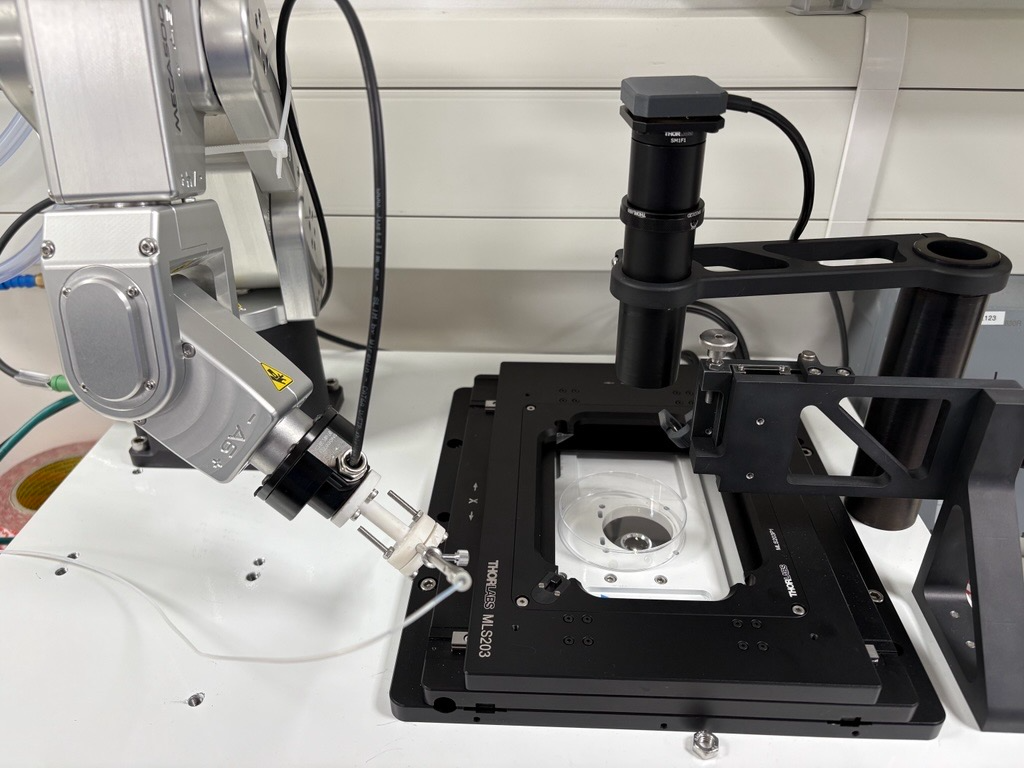
This project will focus on deep learning–driven multimodal microscopic image segmentation and feature recognition, aiming to achieve the first multimodal (image + descriptive label) recognition in ICSI images and enhance robustness across different microscopic systems. In addition, it will research a differentiable perception–control coupling module that connects the visual segmentation network (perception) and a controlled based on reinforcement learning (action).
Back to projects
Differentiable Perception-Control Learning for Intelligent Robotic Micromanipulation in ICSI