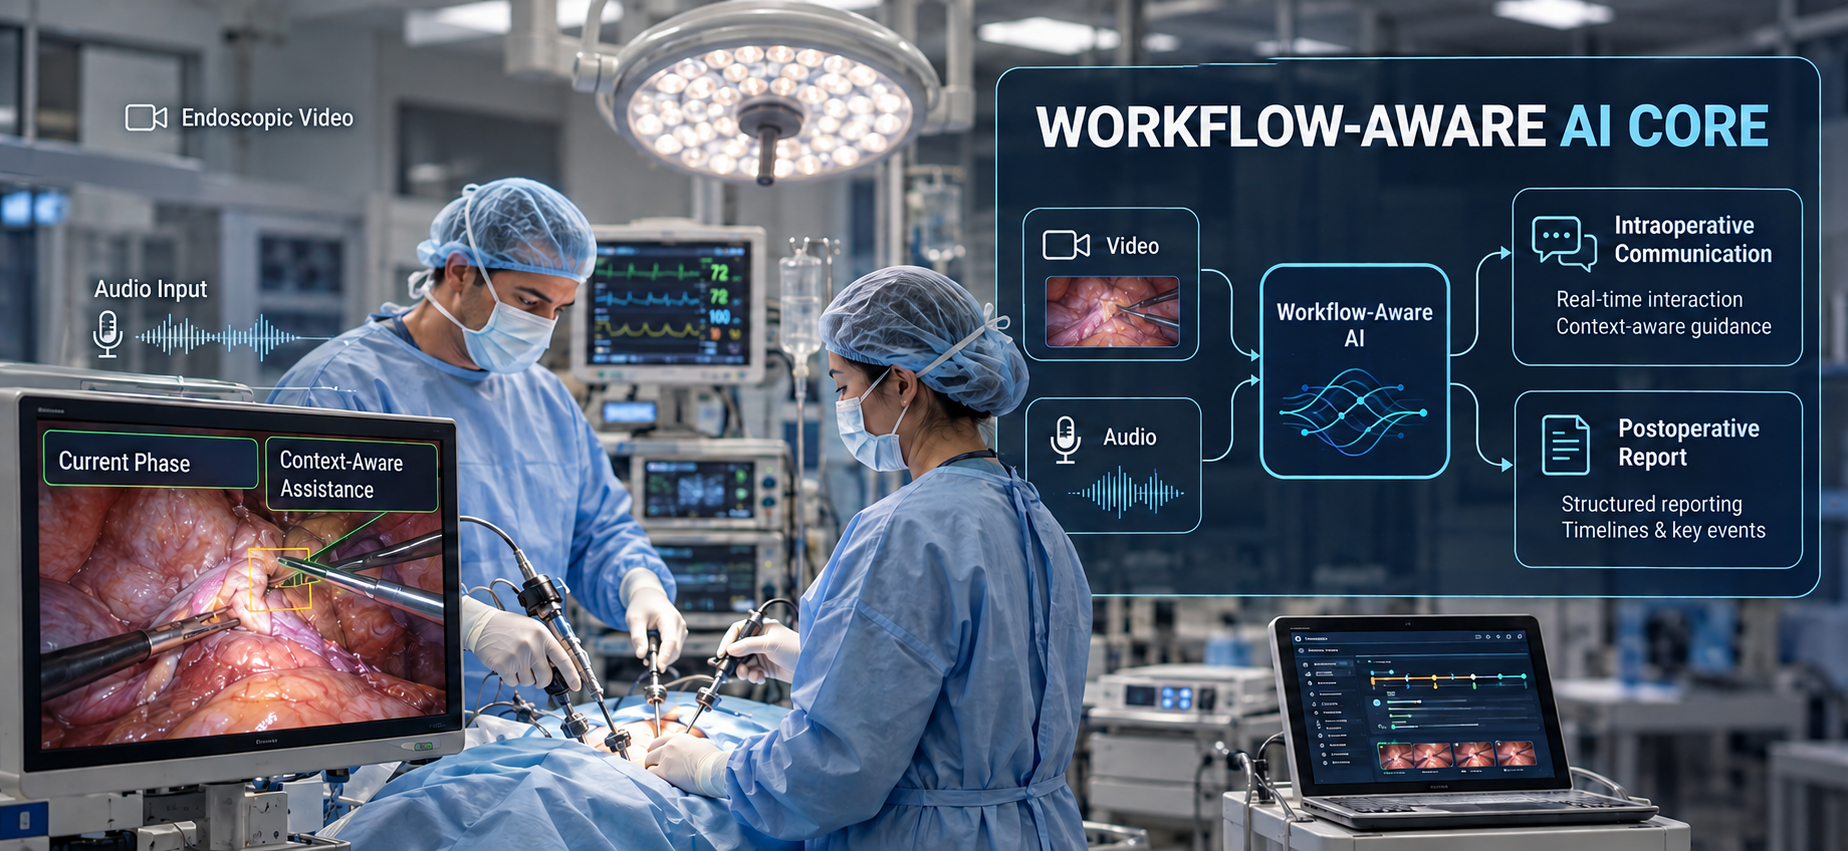
This project aims to develop and evaluate a general multimodal surgical copilot that learns from long-form surgical video and audio. The central research question is how reusable procedural representations can be learned from broad surgical data and used to support real-time workflow-aware interaction and structured postoperative reporting. The project will investigate multimodal temporal modelling, long-context procedural memory, evidence-grounded responses, and interpretable case-level summarisation. The expected outcome is a computational framework that moves beyond isolated surgical AI tasks towards reusable procedural intelligence for surgical review, training and bounded intraoperative assistance
Back to projects
General Copilot for Real-Time Surgical Interaction and Postoperative Reporting