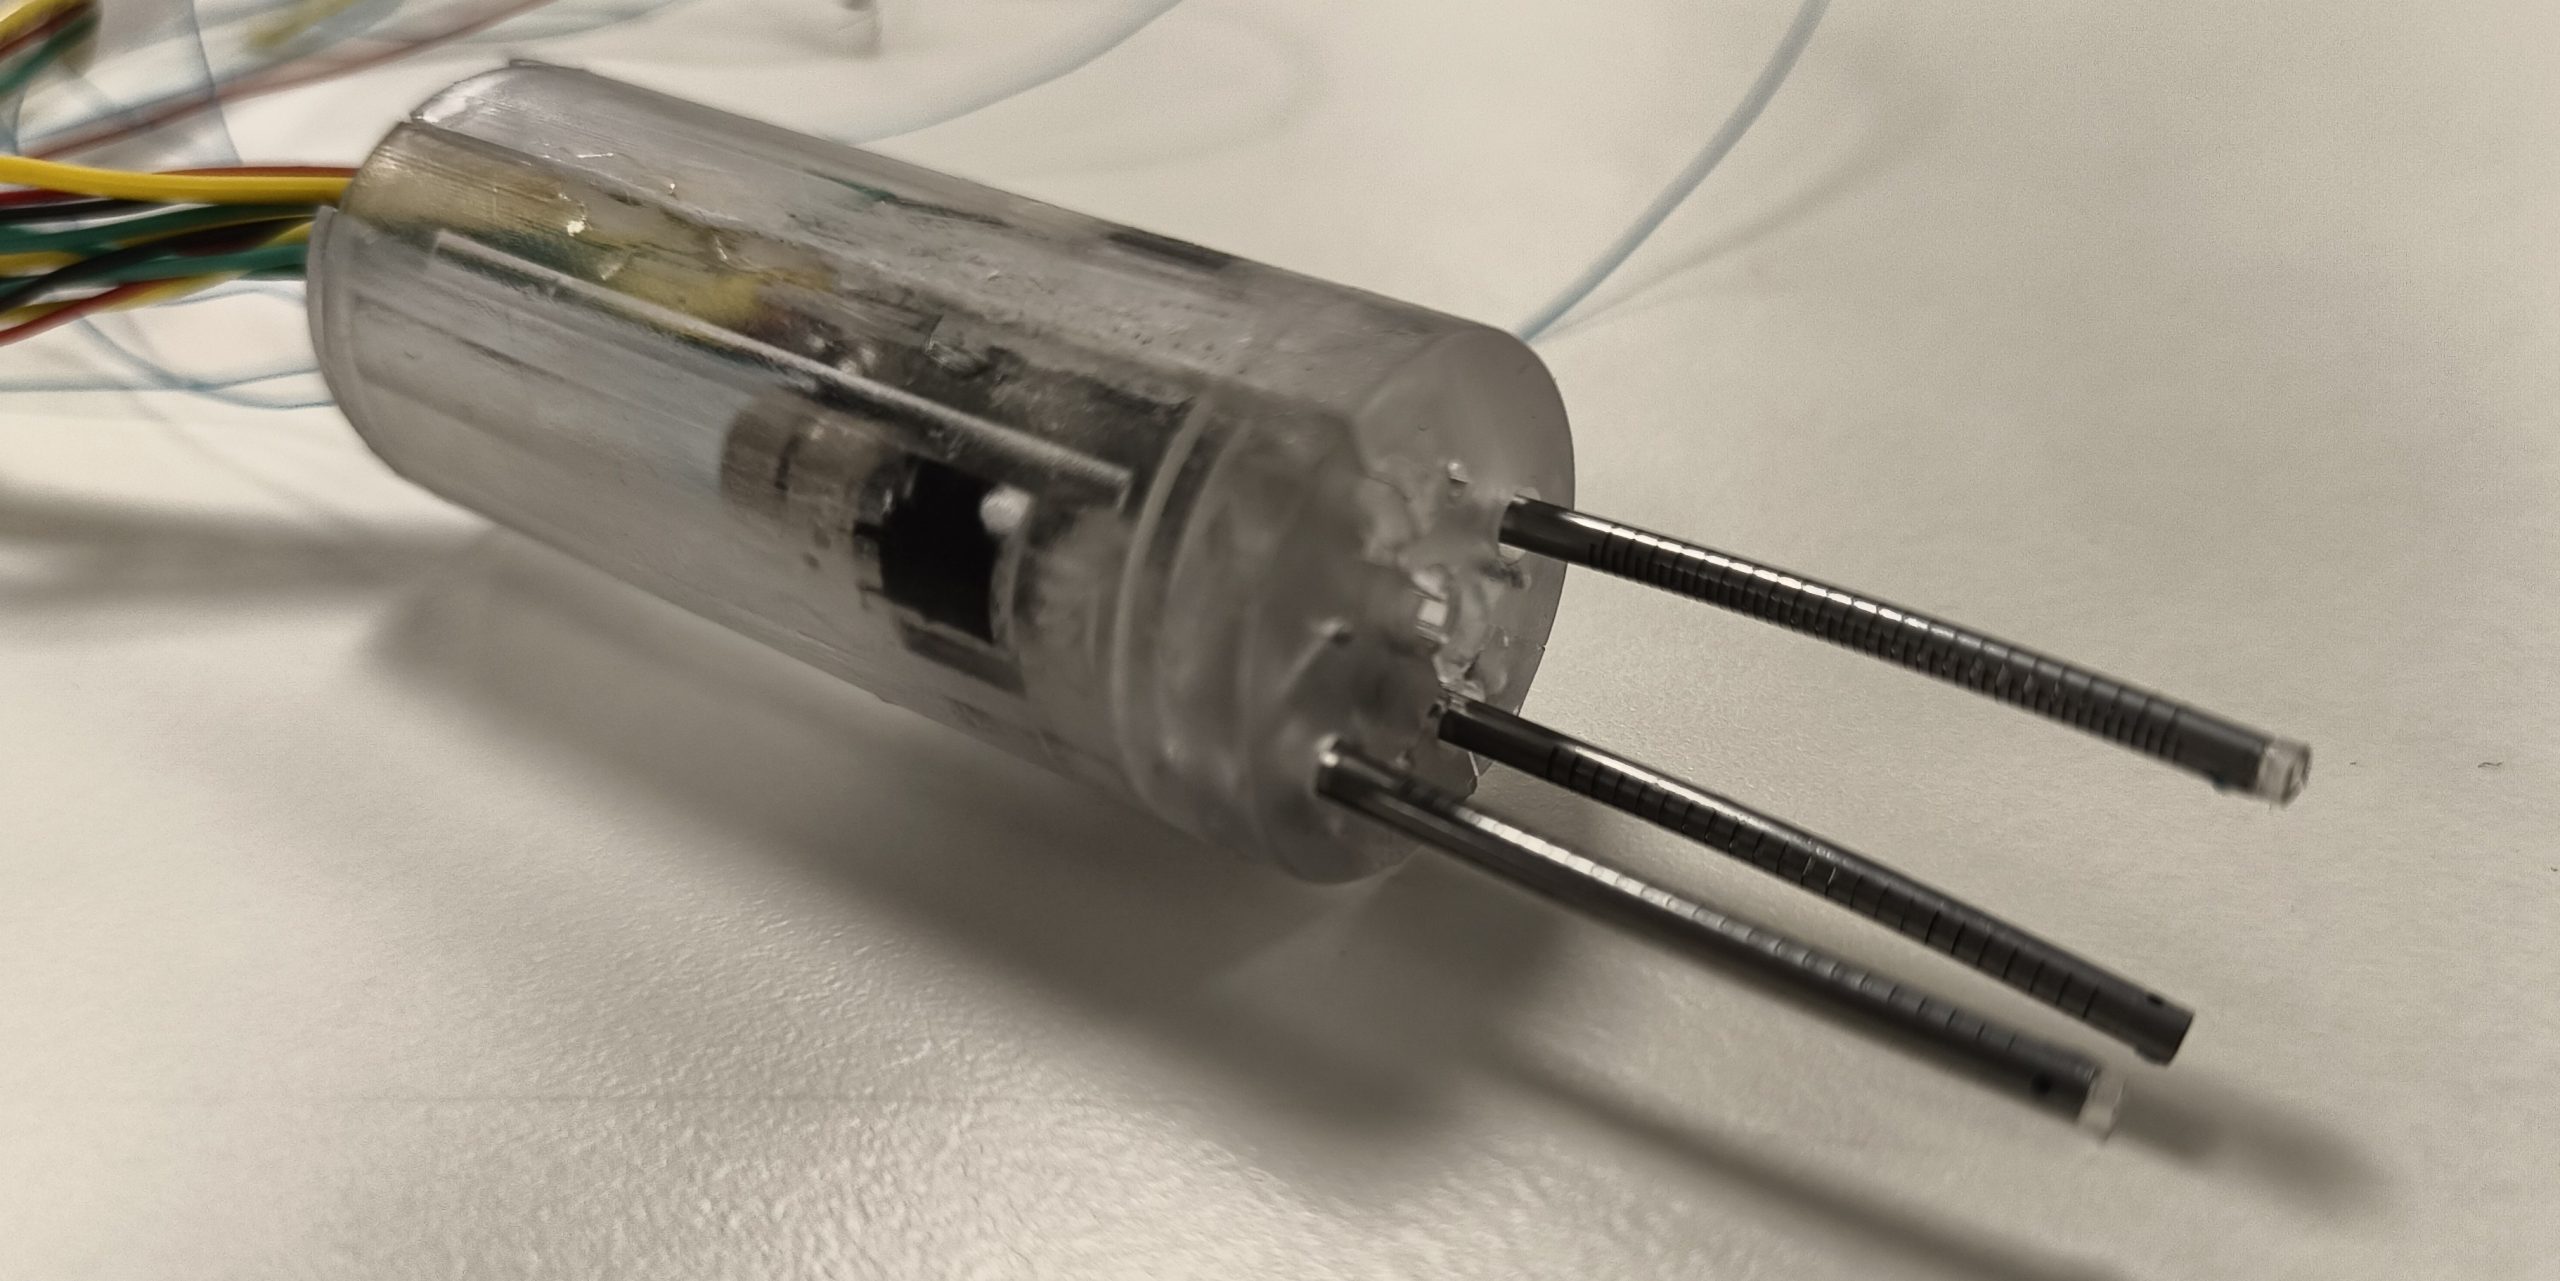
The aim of this project is to develop and experimentally evaluate a novel miniaturized robotic platform that can be deployed for an Endotheranostic colon cancer intervention. Adjoining technologies of the full robotic system and their interfaces must be carefully considered, including end effectors and various sensor modalities required for in-situ tissue examination. Specifically, the project will develop a multi-arm system that leverages flexible robot technology in a small form factor, to enable bimanual interventions deep inside the human colon.
Back to projects
Microrobotic Manipulation for Endotheranostic Interventions