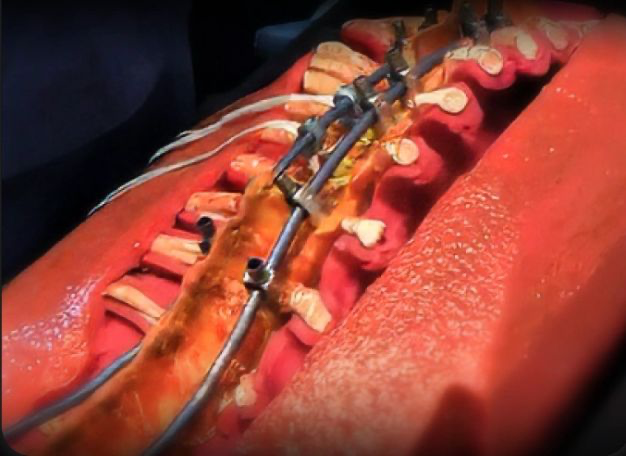
Scoliosis surgery requires accurate pedicle screw placement and deformity correction, making it one of the most technically demanding orthopaedic procedures. This research aims to develop anatomically realistic, force-sensing surgical phantoms for scoliosis training using medical image segmentation, additive manufacturing, and multi-material fabrication techniques. The project will investigate biomimetic materials capable of reproducing the mechanical, tactile, and imaging properties of cortical bone, cancellous bone, and surrounding spinal structures. Force-sensing technologies will be investigated and integrated to provide quantitative feedback during surgical training. Experimental testing will include material characterisation, mechanical testing, and evaluation of integrated force-sensing technologies. The project will also explore adaptation of the developed design and sensing framework to other orthopaedic applications, including shoulder surgery training.
Back to projects
Multi-material, Force-sensing Orthopaedic Phantoms for Surgical Training